CORA
Open-source modular robotic arm platform
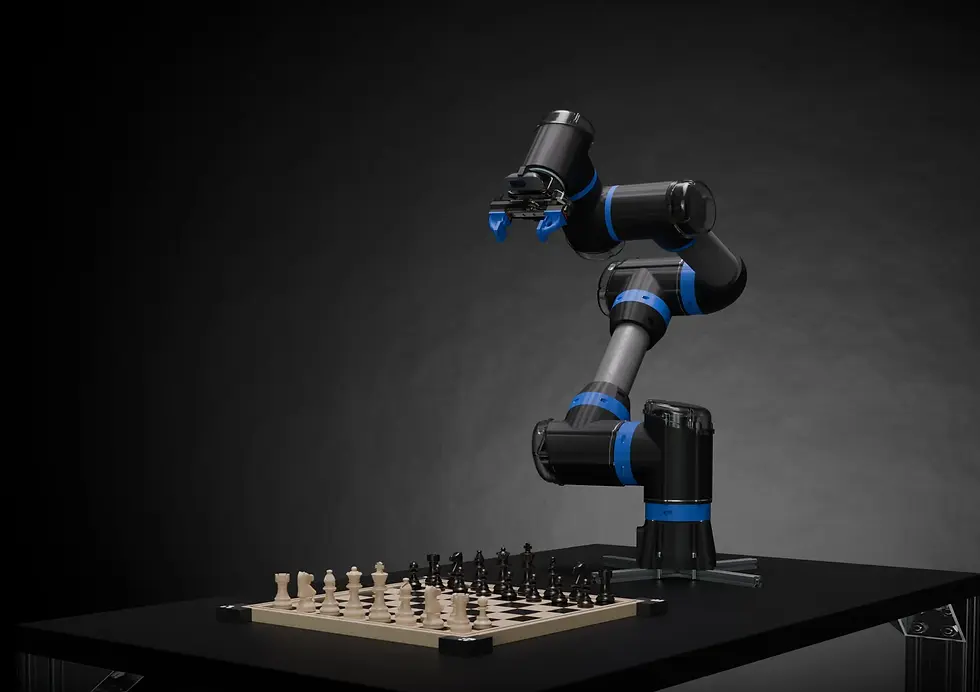
A cost-efficient, accurate cobot robot arm, utilizing cycloidal drives that uses computer vision to autonomously perform tasks using ArUco markers.
The first iteration will be able to play chess autonomously.
Suitable for a wide range of autonomous tasks, as a substitute for expensive robot arms, at a fraction of the price.
Status
Context
Timeline
Open Roles
Software Engineer
This ui not gonna write itself gang
[insert text][insert text][insert text][insert text][insert text][insert text]v
[insert text][insert text][insert text][insert text]
[insert text][insert text][insert text]
[insert text][insert text][insert text]
Electrical Engineer
PCBs are hard bruh, harddddddd
[insert text][insert text][insert text][insert text]
[insert text][insert text]
[insert text][insert text]
[insert text][insert text][insert text]
[insert text]
[insert text]
[insert text][insert text][insert text]
Team Manager
Big Matt aint got time for this, somebody else can play SIMS
We locking in on the engineering
[insert text][insert text][insert text][insert text][insert text][insert text]
[insert text][insert text][insert text]
[insert text][insert text][insert text]
[insert text][insert text][insert text]
Application Details
Add paragraph text. Click “Edit Text” to update the font, size and more. To change and reuse text themes, go to Site Styles.
Application
Find us at
Website


GitHub


YouTube
The Team
Department
Name
Role