RSA Teams
Enduring Legacy
RSA teams are structured to tackle grandiose objectives, it consists of a large team of highly motivated engineers all looking to build something that lasts across many generations of talent.
CORA
Open-source modular robotic arm platform
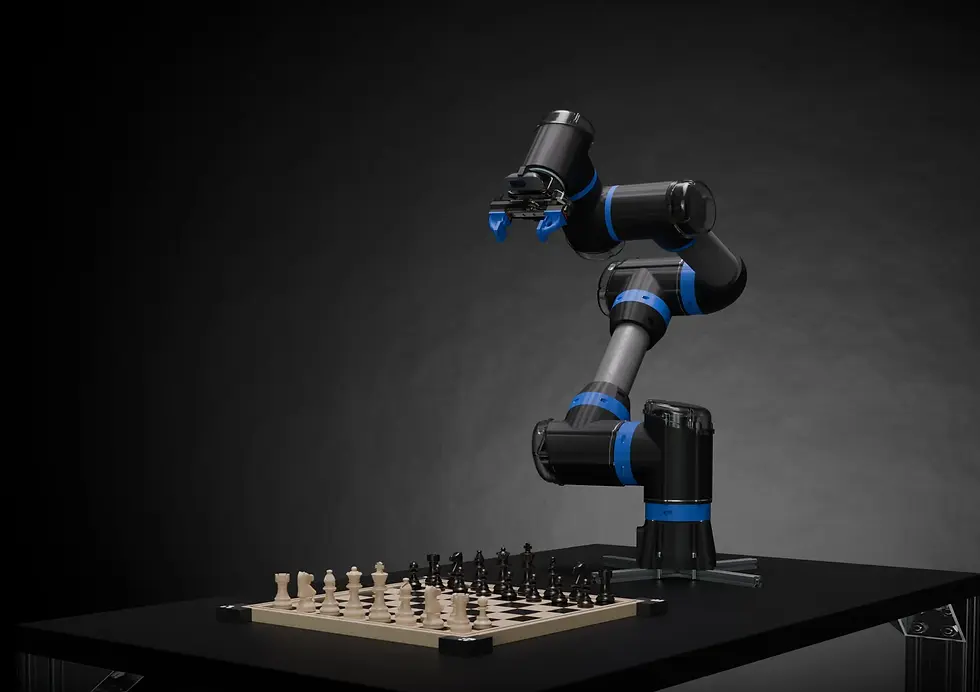
A cost efficient, mostly 3D-printable modular robotic joint system. Each joint is its own package containing an actuator and easy to assemble external connectors.
The system is designed with the intent that users can mix and match the joints in any position and orientation as to make a manipulator that is unique to their project and matches the exact requirements.
Currently the system consists of a pair of revolute joints, standard attatchments, a ROS2 and Python api, and a configurator app wherein users configure their manipulator.
By cutting out the need for mechanical design and prototyping from scratch, CORA offers convenience by streamlining the robotics engineering workflow, while also offering unique solutions to each user.
CORA
Open-source modular robotic arm platform
A cost efficient, mostly 3D-printable modular robotic joint system. Each joint is its own package containing an actuator and easy to assemble external connectors.
The system is designed with the intent that users can mix and match the joints in any position and orientation as to make a manipulator that is unique to their project and matches the exact requirements.
Currently the system consists of a pair of revolute joints, standard attatchments, a ROS2 and Python api, and a configurator app wherein users configure their manipulator.
By cutting out the need for mechanical design and prototyping from scratch, CORA offers convenience by streamlining the robotics engineering workflow, while also offering unique solutions to each user.
Delft Mercurians
RoboCup competition team
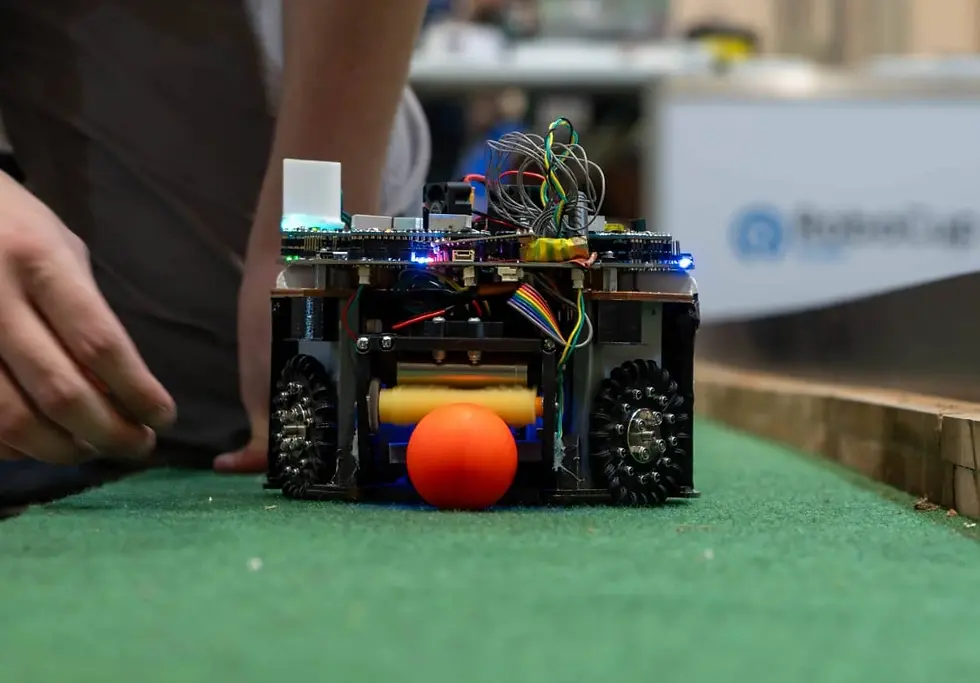
Participating in the RoboCup Small Size League. Developing fully autonomous football robots from the ground up.
Founded in 2022 and have since competed in Eindhoven, The Netherlands (2024) and Salvador, Brazil (2025), and Incheon, Korea (2026).
Project Echo
Open Source Humanoid for Search and Rescue operations
We are exploring the added value that humanoid robots could bring to search and rescue operations in damaged and partially collapsed buildings.
We test this by developing an open-source humanoid designed to meet the demands of these disaster environments and putting it through realistic rescue scenarios in the RoboCup Rescue Competition.
Our aim is to demonstrate that a humanoid can operate in these environments and identify the situations in which its morphology provides added value.